
Ver3.0 🖨️ 3D 프린터 G-code 제어 소스코드 예제로 배우는 실전 프로그래밍 가이드
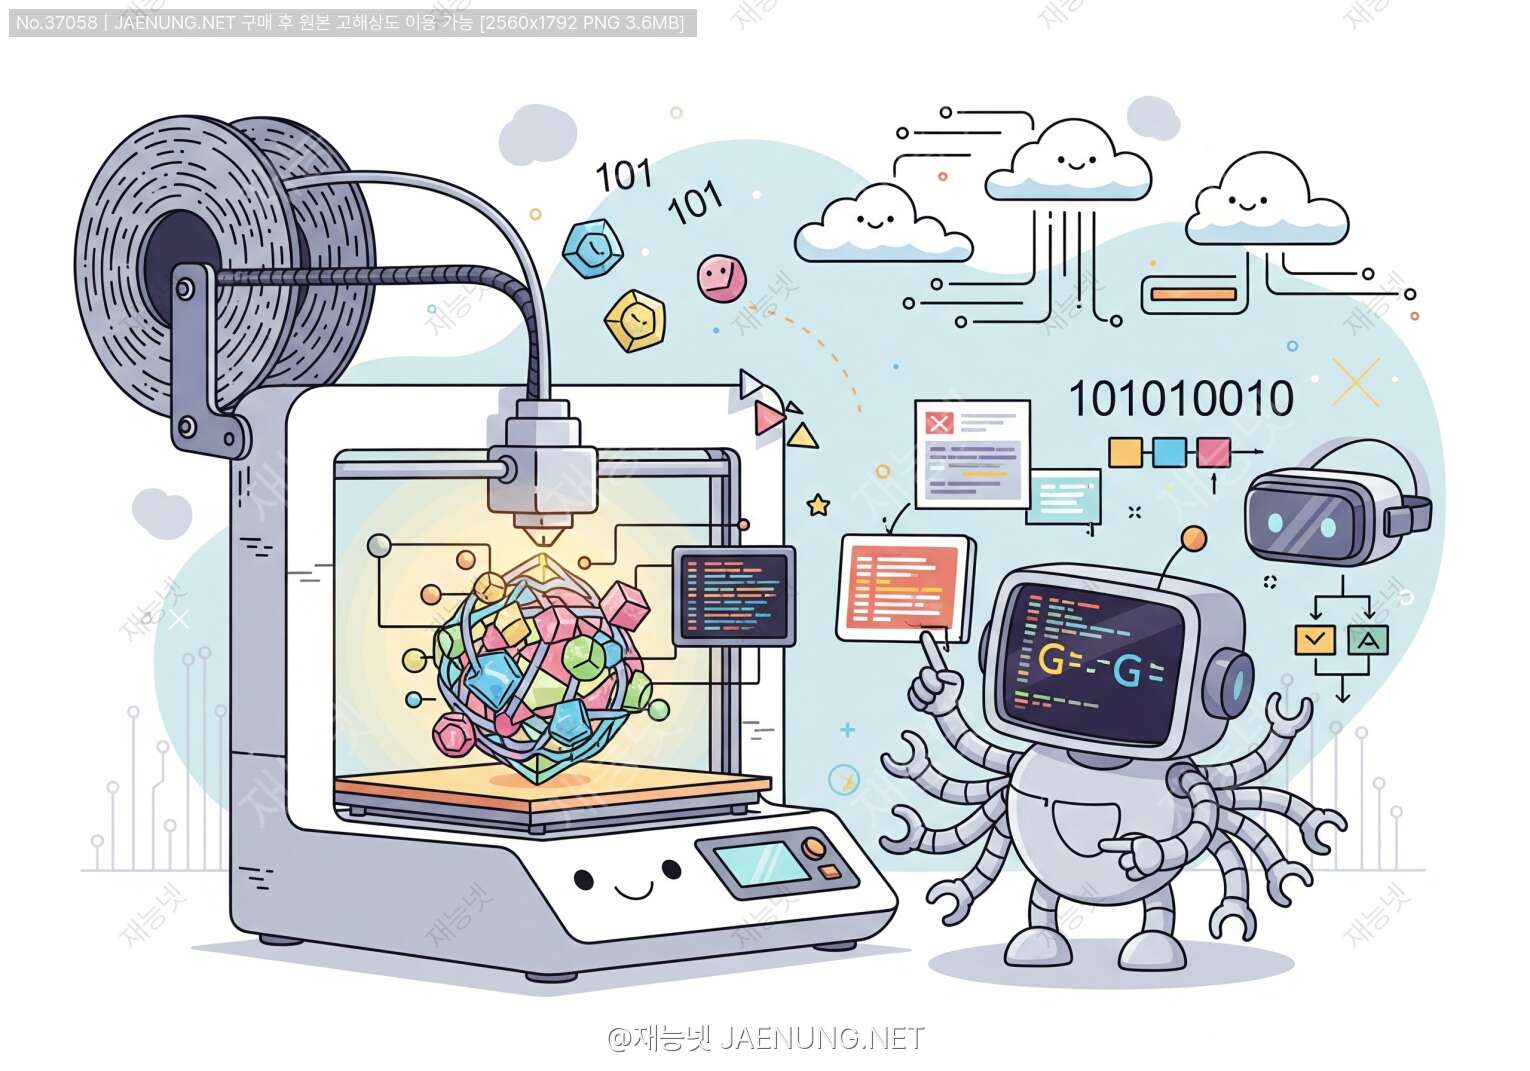
🖨️ 3D 프린터 G-code 제어 소스코드 예제로 배우는 실전 프로그래밍 가이드
초보자도 쉽게 따라하는 G-code 제어 완벽 마스터
안녕! 👋 오늘은 3D 프린터를 제어하는 핵심 언어인 G-code를 프로그래밍으로 다루는 방법에 대해 이야기해볼게. 3D 프린팅에 관심이 있거나, 자동화 시스템을 구축하고 싶다면 이 글이 정말 유용할 거야! 🚀
G-code는 CNC 기계나 3D 프린터를 제어하는 표준 언어인데, 생각보다 간단하면서도 강력한 기능을 가지고 있어. 마치 프린터에게 "여기로 이동해", "이 온도로 가열해", "필라멘트를 이만큼 밀어내" 같은 명령을 내리는 거지. 프로그래밍으로 이걸 제어할 수 있다면? 완전 자동화된 3D 프린팅 시스템을 만들 수 있어! 😎
🎯 G-code가 뭐길래?
G-code는 1950년대 MIT에서 개발된 수치 제어(Numerical Control) 언어야. 원래는 CNC 밀링 머신을 위해 만들어졌지만, 지금은 3D 프린터의 표준 제어 언어로 자리잡았어. 각 명령어는 알파벳 문자와 숫자의 조합으로 이루어져 있고, 한 줄에 하나의 명령을 실행하는 구조야.
📌 G-code의 기본 구조
• G 명령어: 이동, 호밍 등 기본 동작
• M 명령어: 모터, 히터 등 기계 제어
• T 명령어: 툴(노즐) 변경
• 파라미터: X, Y, Z(위치), F(속도), S(온도) 등
예를 들어 G1 X100 Y50 Z10 F1500이라는 명령어를 보면:
- G1: 직선 이동 명령
- X100: X축으로 100mm 위치로
- Y50: Y축으로 50mm 위치로
- Z10: Z축으로 10mm 위치로
- F1500: 속도는 1500mm/min으로
이렇게 간단한 텍스트 명령으로 3D 프린터의 모든 동작을 제어할 수 있다는 게 정말 매력적이지 않아? 🎨
💻 Python으로 G-code 제어하기
가장 많이 사용되는 방법은 Python을 이용한 시리얼 통신이야. 대부분의 3D 프린터는 USB를 통해 시리얼 포트로 연결되고, 이를 통해 G-code 명령을 전송할 수 있어. pySerial 라이브러리를 사용하면 정말 쉽게 구현할 수 있지! 🐍
기본 연결 설정
import serial
import time

class Printer3D:
    def __init__(self, port='/dev/ttyUSB0', baudrate=115200):
        """
        3D 프린터 연결 초기화
        port: 시리얼 포트 (Windows: COM3, Linux: /dev/ttyUSB0)
        baudrate: 통신 속도 (보통 115200 또는 250000)
        """
        self.ser = serial.Serial(port, baudrate, timeout=1)
        time.sleep(2)  # 연결 안정화 대기
        print(f"프린터 연결됨: {port}")

    def send_gcode(self, command):
        """G-code 명령 전송"""
        self.ser.write(f"{command}\n".encode())
        time.sleep(0.1)

        # 응답 읽기
        response = self.ser.readline().decode().strip()
        print(f"전송: {command} | 응답: {response}")
        return response

    def wait_for_ok(self):
        """프린터의 'ok' 응답 대기"""
        while True:
            response = self.ser.readline().decode().strip()
            if 'ok' in response.lower():
                return True
            time.sleep(0.1)

    def close(self):
        """연결 종료"""
        self.ser.close()
        print("프린터 연결 종료")

# 사용 예제
printer = Printer3D('/dev/ttyUSB0', 115200)
printer.send_gcode('G28')  # 홈 포지션으로 이동
printer.wait_for_ok()
printer.close()
💡 TIP: Windows에서는 장치 관리자에서 COM 포트 번호를 확인할 수 있어. Linux나 Mac에서는 ls /dev/tty* 명령으로 확인 가능해!
실전 제어 예제
이제 실제로 프린터를 움직여보자! 간단한 정사각형을 그리는 프로그램을 만들어볼게. 🎯
class PrinterController(Printer3D):
    def __init__(self, port, baudrate=115200):
        super().__init__(port, baudrate)
        self.current_pos = {'X': 0, 'Y': 0, 'Z': 0}

    def home_all(self):
        """모든 축 홈 포지션으로"""
        print("🏠 홈 포지션으로 이동 중...")
        self.send_gcode('G28')
        self.wait_for_ok()
        self.current_pos = {'X': 0, 'Y': 0, 'Z': 0}

    def set_temperature(self, nozzle_temp, bed_temp=0):
        """온도 설정"""
        print(f"🔥 노즐 온도: {nozzle_temp}°C, 베드 온도: {bed_temp}°C")
        self.send_gcode(f'M104 S{nozzle_temp}')  # 노즐 온도 설정
        if bed_temp > 0:
            self.send_gcode(f'M140 S{bed_temp}')  # 베드 온도 설정

    def wait_temperature(self, nozzle_temp):
        """목표 온도 도달 대기"""
        print(f"⏳ 온도 도달 대기 중...")
        self.send_gcode(f'M109 S{nozzle_temp}')
        self.wait_for_ok()

    def move_to(self, x=None, y=None, z=None, speed=1500):
        """지정 위치로 이동"""
        command = 'G1'
        if x is not None:
            command += f' X{x}'
            self.current_pos['X'] = x
        if y is not None:
            command += f' Y{y}'
            self.current_pos['Y'] = y
        if z is not None:
            command += f' Z{z}'
            self.current_pos['Z'] = z
        command += f' F{speed}'

        self.send_gcode(command)

    def extrude(self, amount, speed=300):
        """필라멘트 압출"""
        self.send_gcode(f'G1 E{amount} F{speed}')

    def draw_square(self, size=50, z_height=0.2):
        """정사각형 그리기"""
        print(f"📐 {size}mm 정사각형 그리는 중...")

        # 시작 위치로 이동
        self.move_to(x=10, y=10, z=z_height)
        self.wait_for_ok()

        # 정사각형 그리기
        positions = [
            (10 + size, 10),
            (10 + size, 10 + size),
            (10, 10 + size),
            (10, 10)
        ]

        for x, y in positions:
            self.move_to(x=x, y=y)
            self.extrude(5)  # 이동하면서 필라멘트 압출
            self.wait_for_ok()

        print("✅ 정사각형 완성!")

# 실제 사용
controller = PrinterController('/dev/ttyUSB0')

# 초기화
controller.home_all()
controller.set_temperature(nozzle_temp=200, bed_temp=60)
controller.wait_temperature(200)

# 정사각형 그리기
controller.draw_square(size=50, z_height=0.2)

# 종료
controller.move_to(z=50)  # Z축 올리기
controller.send_gcode('M104 S0')  # 노즐 히터 끄기
controller.send_gcode('M140 S0')  # 베드 히터 끄기
controller.close()
이 코드는 실제로 3D 프린터를 제어해서 50mm 크기의 정사각형을 그려. 온도 설정부터 이동, 압출까지 모든 과정이 자동화되어 있지! 😊
🔧 주요 G-code 명령어 완벽 정리
3D 프린터 제어에 필수적인 G-code 명령어들을 정리해봤어. 이것만 알아도 대부분의 작업이 가능해! 📚
| 명령어 | 기능 | 예제 |
|---|---|---|
| G28 | 홈 포지션으로 이동 | G28 (모든 축), G28 X Y (X, Y축만) |
| G1 | 직선 이동 (압출 포함) | G1 X100 Y50 Z10 F1500 |
| G0 | 빠른 이동 (압출 없음) | G0 X50 Y50 Z20 |
| G92 | 현재 위치 설정 | G92 E0 (압출기 위치 리셋) |
| M104 | 노즐 온도 설정 (대기 안함) | M104 S200 |
| M109 | 노즐 온도 설정 (도달 대기) | M109 S200 |
| M140 | 베드 온도 설정 (대기 안함) | M140 S60 |
| M190 | 베드 온도 설정 (도달 대기) | M190 S60 |
| M106 | 냉각 팬 켜기 | M106 S255 (최대 속도) |
| M107 | 냉각 팬 끄기 | M107 |
🎓 고급 명령어
• G2/G3: 원호 이동 (시계방향/반시계방향)
• M82: 압출기 절대 좌표 모드
• M83: 압출기 상대 좌표 모드
• M84: 모터 비활성화
• M117: LCD에 메시지 표시
• M300: 비프음 재생
🎨 실전 프로젝트: G-code 생성기 만들기
이제 좀 더 실용적인 프로젝트를 만들어볼까? 간단한 도형을 입력받아서 G-code를 자동으로 생성하는 프로그램이야! 이걸 응용하면 복잡한 패턴도 쉽게 만들 수 있어. 🎪
import math

class GCodeGenerator:
    def __init__(self, filename='output.gcode'):
        self.filename = filename
        self.gcode_lines = []
        self.current_e = 0  # 현재 압출 위치

    def add_comment(self, comment):
        """주석 추가"""
        self.gcode_lines.append(f'; {comment}')

    def add_command(self, command):
        """G-code 명령 추가"""
        self.gcode_lines.append(command)

    def start_print(self, nozzle_temp=200, bed_temp=60):
        """프린트 시작 설정"""
        self.add_comment('=== 프린트 시작 ===')
        self.add_command('G28')  # 홈
        self.add_command('G92 E0')  # 압출기 리셋
        self.add_command(f'M104 S{nozzle_temp}')  # 노즐 온도
        self.add_command(f'M140 S{bed_temp}')  # 베드 온도
        self.add_command(f'M109 S{nozzle_temp}')  # 온도 대기
        self.add_command(f'M190 S{bed_temp}')
        self.add_command('G1 Z2.0 F3000')  # Z축 올리기
        self.add_comment('프라임 라인 그리기')
        self.add_command('G1 X10 Y10 Z0.3 F5000')
        self.add_command('G1 X100 Y10 E10 F1500')
        self.add_command('G92 E0')
        self.add_comment('')

    def end_print(self):
        """프린트 종료 설정"""
        self.add_comment('=== 프린트 종료 ===')
        self.add_command('G91')  # 상대 좌표
        self.add_command('G1 E-2 F2700')  # 리트랙션
        self.add_command('G1 Z10 F3000')  # Z축 올리기
        self.add_command('G90')  # 절대 좌표
        self.add_command('G1 X0 Y200 F3000')  # 앞으로 이동
        self.add_command('M104 S0')  # 노즐 히터 끄기
        self.add_command('M140 S0')  # 베드 히터 끄기
        self.add_command('M84')  # 모터 끄기

    def move_to(self, x, y, z=None, speed=3000, extrude=False):
        """위치로 이동"""
        command = 'G1'
        command += f' X{x:.3f} Y{y:.3f}'
        if z is not None:
            command += f' Z{z:.3f}'

        if extrude:
            # 이동 거리 계산
            distance = math.sqrt(x**2 + y**2)
            extrusion = distance * 0.1  # 간단한 압출량 계산
            self.current_e += extrusion
            command += f' E{self.current_e:.5f}'

        command += f' F{speed}'
        self.add_command(command)

    def draw_circle(self, center_x, center_y, radius, z_height=0.2, segments=36):
        """원 그리기"""
        self.add_comment(f'원 그리기: 중심({center_x}, {center_y}), 반지름 {radius}mm')

        for i in range(segments + 1):
            angle = (2 * math.pi * i) / segments
            x = center_x + radius * math.cos(angle)
            y = center_y + radius * math.sin(angle)

            if i == 0:
                self.move_to(x, y, z_height, extrude=False)
            else:
                self.move_to(x, y, extrude=True)

    def draw_rectangle(self, x, y, width, height, z_height=0.2):
        """직사각형 그리기"""
        self.add_comment(f'직사각형 그리기: ({x}, {y}), {width}x{height}mm')

        corners = [
            (x, y),
            (x + width, y),
            (x + width, y + height),
            (x, y + height),
            (x, y)
        ]

        for i, (px, py) in enumerate(corners):
            if i == 0:
                self.move_to(px, py, z_height, extrude=False)
            else:
                self.move_to(px, py, extrude=True)

    def draw_star(self, center_x, center_y, outer_radius, inner_radius,
                  points=5, z_height=0.2):
        """별 그리기"""
        self.add_comment(f'{points}각 별 그리기: 중심({center_x}, {center_y})')

        for i in range(points * 2 + 1):
            angle = (2 * math.pi * i) / (points * 2) - math.pi / 2
            radius = outer_radius if i % 2 == 0 else inner_radius
            x = center_x + radius * math.cos(angle)
            y = center_y + radius * math.sin(angle)

            if i == 0:
                self.move_to(x, y, z_height, extrude=False)
            else:
                self.move_to(x, y, extrude=True)

    def draw_spiral(self, center_x, center_y, start_radius, end_radius,
                    turns=3, z_height=0.2, segments=100):
        """나선 그리기"""
        self.add_comment(f'나선 그리기: {turns}회전')

        for i in range(segments + 1):
            progress = i / segments
            angle = 2 * math.pi * turns * progress
            radius = start_radius + (end_radius - start_radius) * progress
            x = center_x + radius * math.cos(angle)
            y = center_y + radius * math.sin(angle)

            if i == 0:
                self.move_to(x, y, z_height, extrude=False)
            else:
                self.move_to(x, y, extrude=True)

    def save(self):
        """G-code 파일로 저장"""
        with open(self.filename, 'w') as f:
            f.write('\n'.join(self.gcode_lines))
        print(f'✅ G-code 저장 완료: {self.filename}')
        print(f'📊 총 {len(self.gcode_lines)}줄 생성됨')

# 사용 예제
generator = GCodeGenerator('pattern.gcode')

# 프린트 시작
generator.start_print(nozzle_temp=200, bed_temp=60)

# 다양한 도형 그리기
generator.draw_rectangle(20, 20, 40, 30, z_height=0.2)
generator.draw_circle(100, 50, 20, z_height=0.2)
generator.draw_star(150, 50, 25, 12, points=5, z_height=0.2)
generator.draw_spiral(100, 120, 5, 30, turns=5, z_height=0.2)

# 프린트 종료
generator.end_print()

# 파일 저장
generator.save()
이 코드는 원, 사각형, 별, 나선 등 다양한 도형을 G-code로 변환해줘. 실제로 이 파일을 3D 프린터에 넣으면 멋진 패턴이 그려질 거야! 🌟
⚠️ 주의사항: 실제 프린터에서 테스트할 때는 반드시 프린터 설정(베드 크기, 노즐 직경 등)을 확인하고, 처음에는 낮은 속도로 테스트해봐!
🌐 웹 기반 제어 시스템 구축하기
이제 좀 더 멋진 걸 만들어볼까? Flask를 사용해서 웹 브라우저에서 3D 프린터를 제어하는 시스템이야! 스마트폰으로도 제어할 수 있어서 정말 편리해. 📱
from flask import Flask, render_template, request, jsonify
import serial
import threading
import time

app = Flask(__name__)

class WebPrinterController:
    def __init__(self, port='/dev/ttyUSB0', baudrate=115200):
        self.port = port
        self.baudrate = baudrate
        self.ser = None
        self.is_connected = False
        self.status = {
            'temperature': {'nozzle': 0, 'bed': 0},
            'position': {'x': 0, 'y': 0, 'z': 0},
            'state': 'idle'
        }
        self.lock = threading.Lock()

    def connect(self):
        """프린터 연결"""
        try:
            self.ser = serial.Serial(self.port, self.baudrate, timeout=1)
            time.sleep(2)
            self.is_connected = True
            # 상태 모니터링 스레드 시작
            threading.Thread(target=self._monitor_status, daemon=True).start()
            return True
        except Exception as e:
            print(f"연결 실패: {e}")
            return False

    def disconnect(self):
        """연결 종료"""
        if self.ser:
            self.ser.close()
            self.is_connected = False

    def send_command(self, command):
        """명령 전송"""
        if not self.is_connected:
            return {'success': False, 'message': '프린터가 연결되지 않았습니다'}

        try:
            with self.lock:
                self.ser.write(f"{command}\n".encode())
                time.sleep(0.1)
                response = self.ser.readline().decode().strip()
                return {'success': True, 'response': response}
        except Exception as e:
            return {'success': False, 'message': str(e)}

    def _monitor_status(self):
        """상태 모니터링 (백그라운드)"""
        while self.is_connected:
            try:
                # 온도 확인
                self.send_command('M105')
                # 위치 확인
                self.send_command('M114')
                time.sleep(2)
            except:
                pass

    def home(self, axes=''):
        """홈 포지션"""
        command = f'G28 {axes}'
        return self.send_command(command)

    def move(self, x=None, y=None, z=None, speed=3000):
        """이동"""
        command = 'G1'
        if x is not None:
            command += f' X{x}'
        if y is not None:
            command += f' Y{y}'
        if z is not None:
            command += f' Z{z}'
        command += f' F{speed}'
        return self.send_command(command)

    def set_temperature(self, nozzle=None, bed=None):
        """온도 설정"""
        results = []
        if nozzle is not None:
            results.append(self.send_command(f'M104 S{nozzle}'))
        if bed is not None:
            results.append(self.send_command(f'M140 S{bed}'))
        return results

# 전역 컨트롤러 인스턴스
controller = WebPrinterController()

@app.route('/')
def index():
    """메인 페이지"""
    return '''


        <title>3D Printer Web Control</title>
        <meta name="viewport" content="width=device-width, initial-scale=1">


        <h1>🖨️ 3D Printer Web Control</h1>

        <div class="control-panel">
            <h2>연결 관리</h2>
            <button class="button" onclick="connect()">연결</button>
            <button class="button" onclick="disconnect()">연결 해제</button>
            <div class="status" id="connection-status">상태: 연결 안됨</div>
        </div>

        <div class="control-panel">
            <h2>이동 제어</h2>
            <button class="button" onclick="home()">🏠 홈</button>
            <button class="button" onclick="homeZ()">🏠 Z 홈</button>
            <br><br>
            X: <input type="number" id="move-x" value="0">
            Y: <input type="number" id="move-y" value="0">
            Z: <input type="number" id="move-z" value="0">
            <button class="button" onclick="move()">이동</button>
        </div>

        <div class="control-panel">
            <h2>온도 제어</h2>
            노즐: <input type="number" id="temp-nozzle" value="200">°C
            베드: <input type="number" id="temp-bed" value="60">°C
            <button class="button" onclick="setTemperature()">설정</button>
            <button class="button" onclick="coolDown()">냉각</button>
        </div>

        <div class="control-panel">
            <h2>커스텀 명령</h2>
            <input type="text" id="custom-command" placeholder="G-code 입력" style="width: 300px;">
            <button class="button" onclick="sendCustom()">전송</button>
            <div class="status" id="response"></div>
        </div>

        <script>
            function connect() {
                fetch('/api/connect', {method: 'POST'})
                    .then(r => r.json())
                    .then(data => {
                        document.getElementById('connection-status').innerText =
                            data.success ? '상태: 연결됨 ✅' : '상태: 연결 실패 ❌';
                    });
            }

            function disconnect() {
                fetch('/api/disconnect', {method: 'POST'})
                    .then(r => r.json())
                    .then(data => {
                        document.getElementById('connection-status').innerText =
                            '상태: 연결 해제됨';
                    });
            }

            function home() {
                fetch('/api/home', {method: 'POST'});
            }

            function homeZ() {
                fetch('/api/home?axes=Z', {method: 'POST'});
            }

            function move() {
                const x = document.getElementById('move-x').value;
                const y = document.getElementById('move-y').value;
                const z = document.getElementById('move-z').value;
                fetch('/api/move', {
                    method: 'POST',
                    headers: {'Content-Type': 'application/json'},
                    body: JSON.stringify({x: x, y: y, z: z})
                });
            }

            function setTemperature() {
                const nozzle = document.getElementById('temp-nozzle').value;
                const bed = document.getElementById('temp-bed').value;
                fetch('/api/temperature', {
                    method: 'POST',
                    headers: {'Content-Type': 'application/json'},
                    body: JSON.stringify({nozzle: nozzle, bed: bed})
                });
            }

            function coolDown() {
                fetch('/api/temperature', {
                    method: 'POST',
                    headers: {'Content-Type': 'application/json'},
                    body: JSON.stringify({nozzle: 0, bed: 0})
                });
            }

            function sendCustom() {
                const command = document.getElementById('custom-command').value;
                fetch('/api/command', {
                    method: 'POST',
                    headers: {'Content-Type': 'application/json'},
                    body: JSON.stringify({command: command})
                })
                .then(r => r.json())
                .then(data => {
                    document.getElementById('response').innerText =
                        '응답: ' + data.response;
                });
            }
        </script>


    '''

@app.route('/api/connect', methods=['POST'])
def api_connect():
    success = controller.connect()
    return jsonify({'success': success})

@app.route('/api/disconnect', methods=['POST'])
def api_disconnect():
    controller.disconnect()
    return jsonify({'success': True})

@app.route('/api/home', methods=['POST'])
def api_home():
    axes = request.args.get('axes', '')
    result = controller.home(axes)
    return jsonify(result)

@app.route('/api/move', methods=['POST'])
def api_move():
    data = request.json
    result = controller.move(
        x=data.get('x'),
        y=data.get('y'),
        z=data.get('z')
    )
    return jsonify(result)

@app.route('/api/temperature', methods=['POST'])
def api_temperature():
    data = request.json
    results = controller.set_temperature(
        nozzle=data.get('nozzle'),
        bed=data.get('bed')
    )
    return jsonify({'success': True, 'results': results})

@app.route('/api/command', methods=['POST'])
def api_command():
    data = request.json
    result = controller.send_command(data['command'])
    return jsonify(result)

if __name__ == '__main__':
    app.run(host='0.0.0.0', port=5000, debug=True)
이 웹 인터페이스를 실행하면 브라우저에서 http://localhost:5000으로 접속해서 프린터를 제어할 수 있어! 스마트폰으로도 같은 네트워크에서 접속 가능하지. 정말 편리하지 않아? 🎉
🛡️ 안전한 제어를 위한 체크리스트
3D 프린터를 프로그래밍으로 제어할 때는 안전이 정말 중요해. 잘못된 명령으로 프린터가 손상될 수 있거든. 다음 사항들을 꼭 체크해줘! 🔒
✅ 필수 안전 체크사항
1. 이동 범위 제한
프린터의 최대 이동 범위를 초과하지 않도록 검증 로직을 추가해야 해.
class SafePrinterController:
    def __init__(self, max_x=200, max_y=200, max_z=200):
        self.max_x = max_x
        self.max_y = max_y
        self.max_z = max_z

    def validate_position(self, x, y, z):
        """위치 유효성 검사"""
        if x < 0 or x > self.max_x:
            raise ValueError(f"X 좌표 범위 초과: {x} (0-{self.max_x})")
        if y < 0 or y > self.max_y:
            raise ValueError(f"Y 좌표 범위 초과: {y} (0-{self.max_y})")
        if z < 0 or z > self.max_z:
            raise ValueError(f"Z 좌표 범위 초과: {z} (0-{self.max_z})")
        return True

    def safe_move(self, x, y, z):
        """안전한 이동"""
        try:
            self.validate_position(x, y, z)
            # 이동 명령 실행
            print(f"✅ 안전한 이동: X{x} Y{y} Z{z}")
        except ValueError as e:
            print(f"❌ 이동 거부: {e}")
2. 온도 제한
과도한 온도 설정을 방지해야 해. 필라멘트 종류에 따라 적절한 온도 범위가 있거든.
TEMP_LIMITS = {
    'PLA': {'nozzle': (180, 220), 'bed': (50, 70)},
    'ABS': {'nozzle': (220, 250), 'bed': (80, 110)},
    'PETG': {'nozzle': (220, 250), 'bed': (70, 90)},
    'TPU': {'nozzle': (210, 230), 'bed': (40, 60)}
}

def validate_temperature(material, nozzle_temp, bed_temp):
    """온도 유효성 검사"""
    if material not in TEMP_LIMITS:
        raise ValueError(f"지원하지 않는 재료: {material}")

    limits = TEMP_LIMITS[material]

    if not (limits['nozzle'][0] <= nozzle_temp <= limits['nozzle'][1]):
        raise ValueError(
            f"{material} 노즐 온도 범위: "
            f"{limits['nozzle'][0]}-{limits['nozzle'][1]}°C"
        )

    if not (limits['bed'][0] <= bed_temp <= limits['bed'][1]):
        raise ValueError(
            f"{material} 베드 온도 범위: "
            f"{limits['bed'][0]}-{limits['bed'][1]}°C"
        )

    return True
3. 긴급 정지 기능
문제가 발생했을 때 즉시 프린터를 멈출 수 있어야 해.
def emergency_stop(printer):
    """긴급 정지"""
    print("🚨 긴급 정지 실행!")
    printer.send_gcode('M112')  # 긴급 정지
    printer.send_gcode('M104 S0')  # 노즐 히터 끄기
    printer.send_gcode('M140 S0')  # 베드 히터 끄기
    printer.send_gcode('M84')  # 모터 비활성화
    print("✅ 모든 시스템 정지 완료")
4. 연결 상태 모니터링
통신이 끊어졌을 때를 대비한 처리가 필요해.
import time

def send_with_retry(printer, command, max_retries=3):
    """재시도 로직이 있는 명령 전송"""
    for attempt in range(max_retries):
        try:
            response = printer.send_gcode(command)
            if 'ok' in response.lower():
                return True
            print(f"⚠️ 재시도 {attempt + 1}/{max_retries}")
            time.sleep(0.5)
        except Exception as e:
            print(f"❌ 전송 실패: {e}")
            if attempt < max_retries - 1:
                time.sleep(1)
            else:
                print("🚨 최대 재시도 횟수 초과")
                return False
    return False
🎯 실전 활용 사례
이제 실제로 어떻게 활용할 수 있는지 몇 가지 사례를 보여줄게! 이런 프로젝트들은 정말 유용하고 재미있어. 😊
1. 자동 베드 레벨링 시스템
베드 레벨링은 3D 프린팅에서 정말 중요한데, 이걸 자동화할 수 있어!
class AutoBedLeveling:
    def __init__(self, printer):
        self.printer = printer
        self.probe_points = [
            (20, 20),   # 좌측 하단
            (180, 20),  # 우측 하단
            (180, 180), # 우측 상단
            (20, 180),  # 좌측 상단
            (100, 100)  # 중앙
        ]

    def probe_point(self, x, y):
        """특정 지점 프로빙"""
        self.printer.send_gcode(f'G1 X{x} Y{y} Z10 F3000')
        self.printer.send_gcode('G30')  # 프로브 실행
        # 프로브 결과 읽기
        response = self.printer.wait_for_response()
        # Z 높이 추출 (응답 파싱)
        return self.parse_z_height(response)

    def level_bed(self):
        """베드 레벨링 실행"""
        print("🔧 자동 베드 레벨링 시작...")
        heights = []

        for i, (x, y) in enumerate(self.probe_points):
            print(f"📍 포인트 {i+1}/5: ({x}, {y})")
            height = self.probe_point(x, y)
            heights.append(height)
            print(f"   높이: {height:.3f}mm")

        # 높이 차이 계산
        max_diff = max(heights) - min(heights)
        print(f"\n📊 최대 높이 차이: {max_diff:.3f}mm")

        if max_diff > 0.2:
            print("⚠️ 베드 레벨 조정이 필요합니다!")
            self.suggest_adjustments(heights)
        else:
            print("✅ 베드 레벨이 양호합니다!")

    def suggest_adjustments(self, heights):
        """조정 제안"""
        avg = sum(heights) / len(heights)
        corners = ['좌하', '우하', '우상', '좌상']

        print("\n🔧 조정 제안:")
        for i, (height, corner) in enumerate(zip(heights[:4], corners)):
            diff = height - avg
            if abs(diff) > 0.1:
                direction = "올리기" if diff < 0 else "내리기"
                print(f"   {corner} 코너: {abs(diff):.2f}mm {direction}")
2. 프린트 진행 상황 모니터링
프린트가 얼마나 진행됐는지, 남은 시간은 얼마인지 실시간으로 확인할 수 있어!
import time
from datetime import datetime, timedelta

class PrintMonitor:
    def __init__(self, printer, gcode_file):
        self.printer = printer
        self.gcode_file = gcode_file
        self.total_lines = 0
        self.current_line = 0
        self.start_time = None

    def load_gcode(self):
        """G-code 파일 로드"""
        with open(self.gcode_file, 'r') as f:
            self.gcode_lines = [
                line.strip()
                for line in f.readlines()
                if line.strip() and not line.startswith(';')
            ]
        self.total_lines = len(self.gcode_lines)
        print(f"📄 G-code 로드 완료: {self.total_lines}줄")

    def print_with_monitoring(self):
        """모니터링하면서 프린트"""
        self.start_time = datetime.now()

        for i, line in enumerate(self.gcode_lines):
            self.current_line = i + 1

            # G-code 전송
            self.printer.send_gcode(line)
            self.printer.wait_for_ok()

            # 10줄마다 진행 상황 출력
            if i % 10 == 0:
                self.print_progress()

        print("\n🎉 프린트 완료!")
        self.print_summary()

    def print_progress(self):
        """진행 상황 출력"""
        progress = (self.current_line / self.total_lines) * 100
        elapsed = datetime.now() - self.start_time

        # 예상 남은 시간 계산
        if progress > 0:
            total_estimated = elapsed / (progress / 100)
            remaining = total_estimated - elapsed
        else:
            remaining = timedelta(0)

        # 진행 바 생성
        bar_length = 30
        filled = int(bar_length * progress / 100)
        bar = '█' * filled + '░' * (bar_length - filled)

        print(f"\r진행: [{bar}] {progress:.1f}% | "
              f"경과: {self.format_time(elapsed)} | "
              f"남음: {self.format_time(remaining)}", end='')

    def format_time(self, td):
        """시간 포맷팅"""
        total_seconds = int(td.total_seconds())
        hours = total_seconds // 3600
        minutes = (total_seconds % 3600) // 60
        seconds = total_seconds % 60
        return f"{hours:02d}:{minutes:02d}:{seconds:02d}"

    def print_summary(self):
        """프린트 요약"""
        elapsed = datetime.now() - self.start_time
        print(f"\n📊 프린트 요약:")
        print(f"   총 시간: {self.format_time(elapsed)}")
        print(f"   총 라인: {self.total_lines}")
        print(f"   평균 속도: {self.total_lines / elapsed.total_seconds():.1f} 줄/초")

# 사용 예제
monitor = PrintMonitor(printer, 'model.gcode')
monitor.load_gcode()
monitor.print_with_monitoring()
3. 필라멘트 센서 통합
필라멘트가 떨어지면 자동으로 프린트를 일시정지하는 시스템이야!
import RPi.GPIO as GPIO  # 라즈베리파이 사용시

class FilamentSensor:
    def __init__(self, printer, sensor_pin=17):
        self.printer = printer
        self.sensor_pin = sensor_pin
        self.is_printing = False

        # GPIO 설정
        GPIO.setmode(GPIO.BCM)
        GPIO.setup(sensor_pin, GPIO.IN, pull_up_down=GPIO.PUD_UP)
        GPIO.add_event_detect(
            sensor_pin,
            GPIO.FALLING,
            callback=self.on_filament_runout,
            bouncetime=300
        )

    def on_filament_runout(self, channel):
        """필라멘트 부족 감지"""
        if self.is_printing:
            print("\n🚨 필라멘트 부족 감지!")
            self.pause_print()
            self.notify_user()

    def pause_print(self):
        """프린트 일시정지"""
        print("⏸️ 프린트 일시정지 중...")
        self.printer.send_gcode('M600')  # 필라멘트 교체 명령
        # 또는 수동 일시정지
        self.printer.send_gcode('M25')  # SD 카드 프린트 일시정지
        self.printer.send_gcode('G91')  # 상대 좌표
        self.printer.send_gcode('G1 Z10 F300')  # Z축 올리기
        self.printer.send_gcode('G90')  # 절대 좌표

    def notify_user(self):
        """사용자 알림"""
        # 이메일, 푸시 알림 등
        print("📧 사용자에게 알림 전송")
        # 실제로는 이메일이나 텔레그램 봇 등을 사용

    def resume_print(self):
        """프린트 재개"""
        print("▶️ 프린트 재개")
        self.printer.send_gcode('M24')  # SD 카드 프린트 재개
        self.printer.send_gcode('G91')
        self.printer.send_gcode('G1 Z-10 F300')  # Z축 원위치
        self.printer.send_gcode('G90')
🔌 다양한 펌웨어와의 호환성
3D 프린터는 다양한 펌웨어를 사용하는데, 각각 약간씩 다른 명령어를 지원해. 주요 펌웨어들을 알아보자! 🔧
| 펌웨어 | 특징 | 주요 차이점 |
|---|---|---|
| Marlin | 가장 널리 사용되는 오픈소스 펌웨어 | 표준 G-code 완벽 지원, M503으로 설정 확인 |
| Klipper | 라즈베리파이 기반 고성능 펌웨어 | 매크로 지원, 고속 프린팅 최적화 |
| RepRapFirmware | Duet 보드용 펌웨어 | 웹 인터페이스 내장, 고급 설정 가능 |
| Smoothieware | 32비트 보드용 펌웨어 | 부드러운 동작, 설정 파일 기반 |
🔍 펌웨어 감지 코드
def detect_firmware(printer):
    """펌웨어 종류 감지"""
    # M115 명령으로 펌웨어 정보 요청
    response = printer.send_gcode('M115')

    if 'FIRMWARE_NAME:Marlin' in response:
        return 'Marlin'
    elif 'FIRMWARE_NAME:Klipper' in response:
        return 'Klipper'
    elif 'FIRMWARE_NAME:RepRapFirmware' in response:
        return 'RepRapFirmware'
    elif 'Smoothie' in response:
        return 'Smoothieware'
    else:
        return 'Unknown'

def get_firmware_capabilities(firmware):
    """펌웨어별 기능 확인"""
    capabilities = {
        'Marlin': {
            'auto_bed_leveling': True,
            'linear_advance': True,
            'thermal_protection': True,
            'power_loss_recovery': True
        },
        'Klipper': {
            'pressure_advance': True,
            'input_shaping': True,
            'macro_support': True,
            'multi_mcu': True
        },
        'RepRapFirmware': {
            'web_interface': True,
            'mesh_bed_leveling': True,
            'object_cancellation': True,
            'filament_sensors': True
        }
    }
    return capabilities.get(firmware, {})
🎨 고급 기능: 동적 G-code 생성
이제 정말 멋진 걸 만들어볼까? 사용자 입력에 따라 실시간으로 G-code를 생성하는 시스템이야! 예를 들어 텍스트를 입력하면 그걸 3D로 프린트하는 거지. 🚀
from PIL import Image, ImageDraw, ImageFont
import numpy as np

class TextTo3D:
    def __init__(self, generator):
        self.generator = generator

    def text_to_gcode(self, text, font_size=50, layer_height=0.2,
                      extrusion_width=0.4):
        """텍스트를 G-code로 변환"""
        # 이미지로 텍스트 렌더링
        font = ImageFont.truetype('/usr/share/fonts/truetype/dejavu/DejaVuSans-Bold.ttf',
                                   font_size)

        # 텍스트 크기 계산
        dummy_img = Image.new('L', (1, 1))
        draw = ImageDraw.Draw(dummy_img)
        bbox = draw.textbbox((0, 0), text, font=font)
        text_width = bbox[2] - bbox[0]
        text_height = bbox[3] - bbox[1]

        # 실제 이미지 생성
        img = Image.new('L', (text_width + 20, text_height + 20), color=0)
        draw = ImageDraw.Draw(img)
        draw.text((10, 10), text, fill=255, font=font)

        # 이미지를 numpy 배열로 변환
        img_array = np.array(img)

        # G-code 생성 시작
        self.generator.add_comment(f'텍스트 프린트: {text}')
        self.generator.add_command('G92 E0')

        # 이미지를 스캔하면서 G-code 생성
        scale = 0.2  # 1픽셀 = 0.2mm

        for y in range(0, img_array.shape[0], 2):
            line_has_content = False
            start_x = None

            for x in range(img_array.shape[1]):
                if img_array[y, x] > 128:  # 밝은 픽셀
                    if not line_has_content:
                        start_x = x
                        line_has_content = True
                        # 이동 (압출 없음)
                        self.generator.move_to(
                            x * scale,
                            y * scale,
                            z=layer_height,
                            extrude=False
                        )
                    # 압출하면서 이동
                    self.generator.move_to(
                        x * scale,
                        y * scale,
                        extrude=True
                    )
                elif line_has_content:
                    line_has_content = False

        self.generator.add_comment('텍스트 프린트 완료')

    def create_3d_text(self, text, height=5):
        """3D 텍스트 생성 (여러 레이어)"""
        layers = int(height / 0.2)

        for layer in range(layers):
            z = layer * 0.2
            self.generator.add_comment(f'레이어 {layer + 1}/{layers}')
            self.text_to_gcode(text)

        print(f"✅ 3D 텍스트 생성 완료: {layers}개 레이어")

# 사용 예제
generator = GCodeGenerator('text_print.gcode')
text_printer = TextTo3D(generator)

generator.start_print()
text_printer.create_3d_text("HELLO 3D!", height=3)
generator.end_print()
generator.save()
💡 응용 아이디어: 이 기술을 응용하면 QR 코드, 로고, 심지어 사진까지 3D로 프린트할 수 있어! 이미지 처리 기술과 결합하면 무궁무진한 가능성이 있지. 🎨
🌟 재능넷에서 3D 프린팅 재능 공유하기
이렇게 배운 G-code 제어 기술을 재능넷에서 다른 사람들과 공유할 수 있어! 예를 들어 "커스텀 G-code 생성 서비스"나 "3D 프린터 자동화 시스템 구축" 같은 재능을 등록할 수 있지. 프로그래밍과 3D 프린팅을 결합한 독특한 재능은 정말 가치가 높아! 💎
재능넷에서는 이런 전문적인 기술 재능들이 활발하게 거래되고 있어. 3D 프린팅 관련 프로그래밍 강의, 커스텀 슬라이서 개발, 자동화 스크립트 제작 등 다양한 형태로 재능을 나눌 수 있지. 특히 요즘은 개인 제작자들이 많아지면서 이런 기술적 지원에 대한 수요가 정말 높아지고 있어! 🚀
🐛 문제 해결 가이드
실제로 코드를 실행하다 보면 여러 문제에 부딪힐 수 있어. 자주 발생하는 문제들과 해결 방법을 정리해봤어! 🔧
❌ 문제 1: 시리얼 포트 연결 실패
증상:
serial.serialutil.SerialException: could not open port해결 방법:
# Linux/Mac에서 권한 문제 해결
sudo usermod -a -G dialout $USER
# 재로그인 필요

# 포트 자동 감지
import serial.tools.list_ports

def find_printer_port():
    """프린터 포트 자동 감지"""
    ports = serial.tools.list_ports.comports()

    for port in ports:
        print(f"발견된 포트: {port.device} - {port.description}")

        # USB 시리얼 장치 찾기
        if 'USB' in port.description or 'ACM' in port.device:
            try:
                # 테스트 연결
                ser = serial.Serial(port.device, 115200, timeout=1)
                ser.close()
                print(f"✅ 사용 가능한 포트: {port.device}")
                return port.device
            except:
                continue

    return None

# 사용
port = find_printer_port()
if port:
    printer = Printer3D(port)
else:
    print("❌ 프린터를 찾을 수 없습니다")
❌ 문제 2: 명령 응답 없음
증상: G-code를 보내도 프린터가 반응하지 않음
해결 방법:
def send_with_echo(printer, command, timeout=5):
    """에코 확인이 있는 명령 전송"""
    start_time = time.time()

    # 명령 전송
    printer.ser.write(f"{command}\n".encode())

    # 응답 대기
    while time.time() - start_time < timeout:
        if printer.ser.in_waiting:
            response = printer.ser.readline().decode().strip()
            print(f"응답: {response}")

            if 'ok' in response.lower():
                return True
            elif 'error' in response.lower():
                print(f"❌ 에러: {response}")
                return False

        time.sleep(0.1)

    print("⏱️ 타임아웃: 응답 없음")
    return False
❌ 문제 3: 좌표계 혼란
증상: 프린터가 예상과 다른 위치로 이동
해결 방법:
class CoordinateManager:
    def __init__(self):
        self.mode = 'absolute'  # 'absolute' or 'relative'
        self.current_pos = {'X': 0, 'Y': 0, 'Z': 0, 'E': 0}

    def set_absolute(self):
        """절대 좌표 모드"""
        self.mode = 'absolute'
        return 'G90'

    def set_relative(self):
        """상대 좌표 모드"""
        self.mode = 'relative'
        return 'G91'

    def calculate_move(self, x=None, y=None, z=None):
        """이동 계산"""
        if self.mode == 'absolute':
            # 절대 좌표: 그대로 사용
            return {'X': x, 'Y': y, 'Z': z}
        else:
            # 상대 좌표: 현재 위치에서 더함
            return {
                'X': self.current_pos['X'] + (x or 0),
                'Y': self.current_pos['Y'] + (y or 0),
                'Z': self.current_pos['Z'] + (z or 0)
            }

    def update_position(self, x=None, y=None, z=None):
        """위치 업데이트"""
        if x is not None:
            self.current_pos['X'] = x
        if y is not None:
            self.current_pos['Y'] = y
        if z is not None:
            self.current_pos['Z'] = z
⚠️ 중요: 항상 프린트 시작 전에 G90(절대 좌표)과 G92 E0(압출기 리셋)을 실행해서 좌표계를 초기화하는 게 좋아!
📚 추가 학습 리소스
더 깊이 공부하고 싶다면 이런 리소스들을 참고해봐! 📖
🔗 유용한 링크들
• Marlin 공식 문서: G-code 명령어 완벽 레퍼런스
• RepRap Wiki: 3D 프린팅 기술 백과사전
• OctoPrint API: 웹 기반 프린터 제어 시스템
• Klipper 문서: 고급 프린터 제어 기법
• GitHub: 오픈소스 3D 프린팅 프로젝트들
📦 추천 라이브러리
• pySerial: 시리얼 통신의 기본
• printrun: 프린터 제어 유틸리티
• CuraEngine: 슬라이싱 엔진
• trimesh: 3D 메시 처리
• numpy-stl: STL 파일 처리
🎯 마무리하며
자, 여기까지 3D 프린터 G-code 제어에 대해 정말 많은 걸 배웠어! 기본적인 시리얼 통신부터 시작해서 웹 인터페이스, 자동화 시스템, 심지어 텍스트를 3D로 변환하는 것까지 다뤘지. 😊
이 기술들을 마스터하면 단순히 STL 파일을 프린트하는 것을 넘어서, 완전히 자동화된 3D 프린팅 시스템을 구축할 수 있어. 상상해봐 - 웹에서 주문을 받으면 자동으로 G-code를 생성하고, 프린터가 알아서 출력하고, 완료되면 알림을 보내는 시스템을! 🚀
프로그래밍과 하드웨어 제어를 결합하는 건 정말 재미있고 보람찬 일이야. 처음에는 어려워 보일 수 있지만, 하나씩 따라하다 보면 어느새 전문가가 되어 있을 거야. 그리고 이런 기술은 3D 프린팅뿐만 아니라 CNC, 레이저 커터, 로봇 팔 등 다양한 분야에도 응용할 수 있어! 💪
혹시 막히는 부분이 있거나 더 궁금한 게 있다면, 커뮤니티에 질문하거나 직접 실험해보는 걸 추천해. 실제로 프린터를 움직여보면서 배우는 게 가장 빠르고 재미있거든! 안전만 잘 지키면서 말이야. 😉
자, 이제 당신도 3D 프린터 제어 마스터가 될 준비가 됐어! 멋진 프로젝트 만들어보고, 혹시 재능넷에서 이 기술을 공유하고 싶다면 언제든지 도전해봐. 당신의 창의적인 아이디어가 누군가에게는 정말 큰 도움이 될 수 있으니까! 🌟
행복한 프린팅 되길 바라! 화이팅! 🎉🖨️✨

댓글 작성
이 글에 대한 여러분의 생각을 들려주세요
로그인이 필요합니다
댓글을 작성하려면 먼저 로그인해주세요.
댓글 0
지식인의 숲 - 지적 재산권 보호 고지
지적 재산권 보호 고지
- 저작권 및 소유권: 본 컨텐츠는 재능넷의 독점 AI 기술로 생성되었으며, 대한민국 저작권법 및 국제 저작권 협약에 의해 보호됩니다.
- AI 생성 컨텐츠의 법적 지위: 본 AI 생성 컨텐츠는 재능넷의 지적 창작물로 인정되며, 관련 법규에 따라 저작권 보호를 받습니다.
- 사용 제한: 재능넷의 명시적 서면 동의 없이 본 컨텐츠를 복제, 수정, 배포, 또는 상업적으로 활용하는 행위는 엄격히 금지됩니다.
- 데이터 수집 금지: 본 컨텐츠에 대한 무단 스크래핑, 크롤링, 및 자동화된 데이터 수집은 법적 제재의 대상이 됩니다.
- AI 학습 제한: 재능넷의 AI 생성 컨텐츠를 타 AI 모델 학습에 무단 사용하는 행위는 금지되며, 이는 지적 재산권 침해로 간주됩니다.



아직 댓글이 없습니다.